
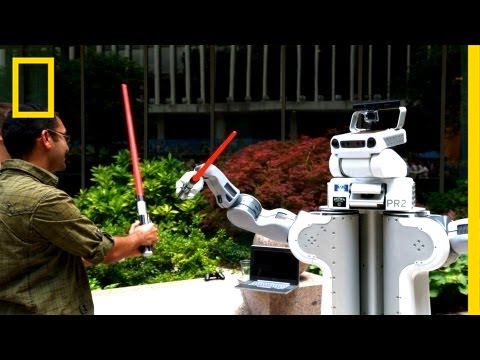
I think everybody looks at the robot describe their own human features to it
describe their own human features to it
describe their own human features to it because it does have two sets of cameras
because it does have two sets of cameras
because it does have two sets of cameras that sort of look like eyes it is sort
that sort of look like eyes it is sort
that sort of look like eyes it is sort of designed to give you a sense of being
of designed to give you a sense of being
of designed to give you a sense of being a person and working in human spaces
what we’re really trying to do is get
what we’re really trying to do is get robots out of the lab and into use with
robots out of the lab and into use with
robots out of the lab and into use with people and figure out you know how a
people and figure out you know how a
people and figure out you know how a robot is going to be able to help people
robot is going to be able to help people
robot is going to be able to help people do more accomplish more things and also
do more accomplish more things and also
do more accomplish more things and also improve the quality of life of everybody
improve the quality of life of everybody
improve the quality of life of everybody across society there are certain
across society there are certain
across society there are certain examples that we think are really
examples that we think are really
examples that we think are really compelling being able to assist the
compelling being able to assist the
compelling being able to assist the disabled being able to help their
disabled being able to help their
disabled being able to help their elderly but the real barriers to entry
elderly but the real barriers to entry
elderly but the real barriers to entry right now are accessibility robots still
right now are accessibility robots still
right now are accessibility robots still cost a lot they’re still difficult to
cost a lot they’re still difficult to
cost a lot they’re still difficult to interface with traditionally I’ve worked
interface with traditionally I’ve worked
interface with traditionally I’ve worked in the areas of robot learning from
in the areas of robot learning from
in the areas of robot learning from demonstration where we don’t have to be
demonstration where we don’t have to be
demonstration where we don’t have to be a programmer to control the robot to
a programmer to control the robot to
a programmer to control the robot to program the robot there’s many different
program the robot there’s many different
program the robot there’s many different ways you can actually teach a robot one
ways you can actually teach a robot one
ways you can actually teach a robot one is you can just show the robot what you
is you can just show the robot what you
is you can just show the robot what you want to do you can have the robot watch
want to do you can have the robot watch
want to do you can have the robot watch you do something that’s really hard
you do something that’s really hard
you do something that’s really hard because the robot now has to track your
because the robot now has to track your
because the robot now has to track your movements and has to perceive what are
movements and has to perceive what are
movements and has to perceive what are the things that you’re interacting with
the things that you’re interacting with
the things that you’re interacting with a much easier approach is to just take
a much easier approach is to just take
a much easier approach is to just take the take the robots arm and guide the
the take the robots arm and guide the
the take the robots arm and guide the robots arm through the emotions that you
robots arm through the emotions that you
robots arm through the emotions that you wanted to execute another approach is to
wanted to execute another approach is to
wanted to execute another approach is to treat the robot as a remote control
treat the robot as a remote control
treat the robot as a remote control device
device
device you take the robots perspective and your
you take the robots perspective and your
you take the robots perspective and your joy sticking the robot through the
joy sticking the robot through the
joy sticking the robot through the actions you want it to execute once we
actions you want it to execute once we
actions you want it to execute once we do those demonstrations our task is to
do those demonstrations our task is to
do those demonstrations our task is to take that data applies machine learning
take that data applies machine learning
take that data applies machine learning and and statistical techniques to it
and and statistical techniques to it
and and statistical techniques to it such that we can extract essentially a
such that we can extract essentially a
such that we can extract essentially a mapping from what the robot sees at a
mapping from what the robot sees at a
mapping from what the robot sees at a given time to what what action would
given time to what what action would
given time to what what action would want it to take we’d love to make it
want it to take we’d love to make it
want it to take we’d love to make it based on what we call natural language
based on what we call natural language
based on what we call natural language commands so that you can you can sell
commands so that you can you can sell
commands so that you can you can sell the robot you know can you pick up that
the robot you know can you pick up that
the robot you know can you pick up that glass for me and it would it would pick
glass for me and it would it would pick
glass for me and it would it would pick up the glass for you I just want to show
up the glass for you I just want to show
up the glass for you I just want to show the the suitable technologies beam
the the suitable technologies beam
the the suitable technologies beam remote presence device so I can access
remote presence device so I can access
remote presence device so I can access this system from anywhere around the
this system from anywhere around the
this system from anywhere around the world so I was sitting right here where
world so I was sitting right here where
world so I was sitting right here where Aaron sitting this morning I was like
Aaron sitting this morning I was like
Aaron sitting this morning I was like all right I just want to go check in on
all right I just want to go check in on
all right I just want to go check in on the lab so I beamed into into this
the lab so I beamed into into this
the lab so I beamed into into this system and essentially drove around my
system and essentially drove around my
system and essentially drove around my lab I can just do this myself in
lab I can just do this myself in
lab I can just do this myself in addition to not being reliant upon
addition to not being reliant upon
addition to not being reliant upon somebody to just be there to take the
somebody to just be there to take the
somebody to just be there to take the call
call
call I can also effect physical change in the
I can also effect physical change in the
I can also effect physical change in the world literally change the world
world literally change the world
world literally change the world robotics is really an extension of the
robotics is really an extension of the
robotics is really an extension of the information technology revolutions that
information technology revolutions that
information technology revolutions that we’ve had over the past few decades
we’ve had over the past few decades
we’ve had over the past few decades what computing data over the last 40
what computing data over the last 40
what computing data over the last 40 years are the same things that robotics
years are the same things that robotics
years are the same things that robotics will provide now except that we have
will provide now except that we have
will provide now except that we have more more wisdom about the technology to
more more wisdom about the technology to
more more wisdom about the technology to do it better to make it you know to not
do it better to make it you know to not
do it better to make it you know to not just think about how these systems are
just think about how these systems are
just think about how these systems are going to improve our productivity and
going to improve our productivity and
going to improve our productivity and help us do do more but also think about
help us do do more but also think about
help us do do more but also think about how we can improve everybody’s life
how we can improve everybody’s life
how we can improve everybody’s life across the world across the
across the world across the
across the world across the socio-economic spectrum
”
Be First to Comment